


Signal Integrity in Surgical Robotics
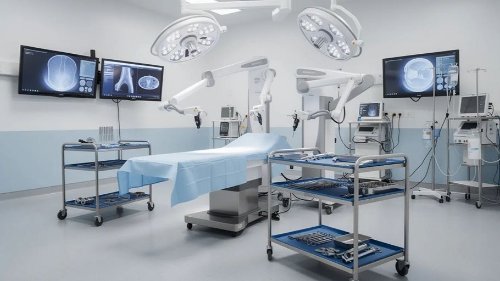
Surgical robots depend on fast, accurate communication between cameras, sensors, processors, motor controls, and user interfaces. When signals move through a compact electromechanical system, even a small loss of integrity can affect image quality, sensor accuracy, communication timing, or motion-control performance.
For PCB designers, the challenge is not simply routing high-speed signals. It is protecting sensitive information while motors switch, power converters operate, processors generate heat, and multiple subsystems work in close proximity. Signal integrity must be addressed as part of the entire board architecture, from stackup and placement through fabrication and assembly.
Functional zoning provides a strong starting point. Imaging and sensor circuits should be physically separated from motor drives and power-conversion sections. High-current paths should be short and direct. Sensitive analog traces should not run parallel to fast digital lines or switching nodes for long distances.
Placement matters as much as routing. Connectors, processors, converters, and motor-control components should be positioned so critical signals can travel through controlled areas without crossing noisy sections of the board.
High-speed interfaces often require controlled impedance. Trace geometry, dielectric thickness, copper weight, and material properties must work together to achieve the specified impedance. Continuous reference planes also give return currents a predictable path and reduce loop area.
Designers should avoid routing critical signals across plane splits or other interruptions in the return path. When a return current must detour around a gap, the larger loop can increase radiation, susceptibility, and crosstalk. Working with the PCB manufacturer before layout is finalized helps ensure that the proposed stackup is both electrically effective and manufacturable.
Differential pairs should maintain consistent spacing, reference planes, and impedance. Length matching should reflect the timing requirements of the interface rather than a generic rule. Vias, connectors, and layer transitions should be evaluated because each introduces a discontinuity.
Low-level analog sensor circuits require additional care. Filtering, grounding, shielding, and component placement should be planned around the sensor’s bandwidth and output level. Keeping amplification and conversion stages close to the signal source can reduce the distance traveled by vulnerable analog signals.
Encoder and position-sensor routing should be isolated from motor phases and switching nodes. Power delivery also needs close attention. Voltage disturbances can create timing errors, increase noise, or affect the performance of sensitive components. Decoupling capacitors, power-plane design, grounding, and regulator placement should be considered together rather than as separate tasks.
The goal is to use advanced construction where it improves signal paths, component placement, or system packaging. Layer transitions, via structures, and escape routing must still preserve reference continuity and manufacturability. A denser board is only successful if it can be produced consistently and performs as intended.
The fabrication drawing should clearly define the approved stackup, impedance targets and tolerances, materials, copper weights, finished thickness, and applicable testing requirements. Clear documentation reduces interpretation and helps preserve the intended electrical performance as the design moves from prototype to production.
AdvancedPCB supports surgical robotics programs with engineering review, controlled-impedance manufacturing, HDI, advanced materials, flex and rigid-flex capabilities, quick-turn prototypes, and a path to production. Involving the PCB manufacturer early can help engineering teams identify signal-integrity and manufacturability risks while changes are still practical.
To discuss an upcoming surgical robotics PCB project, visit AdvancedPCB's robotics page.
For PCB designers, the challenge is not simply routing high-speed signals. It is protecting sensitive information while motors switch, power converters operate, processors generate heat, and multiple subsystems work in close proximity. Signal integrity must be addressed as part of the entire board architecture, from stackup and placement through fabrication and assembly.
Start With the Complete Signal Path
Before layout begins, identify every circuit that depends on clean, predictable signal transmission. In a surgical robotic system, that may include:- High-resolution imaging interfaces
- Position, force, pressure, and torque sensors
- Encoders and motion-feedback circuits
- Processor, memory, and communications buses
- Motor-control feedback loops
- Safety and system-monitoring circuits
Separate Sensitive Signals From Noise Sources
Surgical robotics combines low-level sensor signals with potential noise sources such as motors, switching regulators, clocks, and high-current power circuits. Placing these functions too close together can introduce electromagnetic interference, ground noise, or unwanted coupling.Functional zoning provides a strong starting point. Imaging and sensor circuits should be physically separated from motor drives and power-conversion sections. High-current paths should be short and direct. Sensitive analog traces should not run parallel to fast digital lines or switching nodes for long distances.
Placement matters as much as routing. Connectors, processors, converters, and motor-control components should be positioned so critical signals can travel through controlled areas without crossing noisy sections of the board.
Build the Stackup Around Signal Performance
The PCB stackup determines how signals reference planes, how effectively return currents are contained, and how much isolation exists between circuit groups. It should be defined early, not after routing has begun.High-speed interfaces often require controlled impedance. Trace geometry, dielectric thickness, copper weight, and material properties must work together to achieve the specified impedance. Continuous reference planes also give return currents a predictable path and reduce loop area.
Designers should avoid routing critical signals across plane splits or other interruptions in the return path. When a return current must detour around a gap, the larger loop can increase radiation, susceptibility, and crosstalk. Working with the PCB manufacturer before layout is finalized helps ensure that the proposed stackup is both electrically effective and manufacturable.
Protect Imaging and Sensor Data
Clear imaging and accurate sensing are central to many surgical robotic systems. Noise, timing errors, or signal loss can reduce the quality of the information available to the system and its operator.Differential pairs should maintain consistent spacing, reference planes, and impedance. Length matching should reflect the timing requirements of the interface rather than a generic rule. Vias, connectors, and layer transitions should be evaluated because each introduces a discontinuity.
Low-level analog sensor circuits require additional care. Filtering, grounding, shielding, and component placement should be planned around the sensor’s bandwidth and output level. Keeping amplification and conversion stages close to the signal source can reduce the distance traveled by vulnerable analog signals.
Keep Motion Control Predictable
Precision motion depends on timely feedback between sensors, processors, and actuators. The PCB must support this exchange without allowing motor noise or power fluctuations to interfere with feedback signals.Encoder and position-sensor routing should be isolated from motor phases and switching nodes. Power delivery also needs close attention. Voltage disturbances can create timing errors, increase noise, or affect the performance of sensitive components. Decoupling capacitors, power-plane design, grounding, and regulator placement should be considered together rather than as separate tasks.
Manage Density Without Compromising the Signal Path
Space constraints may drive the use of HDI construction, microvias, via-in-pad, blind or buried vias, and fine-line routing. These technologies can shorten interconnections and create more routing channels, but density alone should not determine the design.The goal is to use advanced construction where it improves signal paths, component placement, or system packaging. Layer transitions, via structures, and escape routing must still preserve reference continuity and manufacturability. A denser board is only successful if it can be produced consistently and performs as intended.
Validate the Design Before Release
Signal-integrity review should happen before fabrication files are released. Important checks include controlled-impedance requirements, differential-pair geometry, return-path continuity, spacing between noisy and sensitive circuits, via transitions, and connector assignments.The fabrication drawing should clearly define the approved stackup, impedance targets and tolerances, materials, copper weights, finished thickness, and applicable testing requirements. Clear documentation reduces interpretation and helps preserve the intended electrical performance as the design moves from prototype to production.
AdvancedPCB supports surgical robotics programs with engineering review, controlled-impedance manufacturing, HDI, advanced materials, flex and rigid-flex capabilities, quick-turn prototypes, and a path to production. Involving the PCB manufacturer early can help engineering teams identify signal-integrity and manufacturability risks while changes are still practical.
To discuss an upcoming surgical robotics PCB project, visit AdvancedPCB's robotics page.

AdvancedPCB
FAQs for Signal Integrity in Surgical Robotics
How can PCB designers reduce electrical noise in a surgical robot?
How does HDI support surgical robotics PCB designs?
When does a surgical robotics PCB require controlled impedance?
When should a PCB manufacturer become involved in the robotic design?
Why is signal integrity important in surgical robotics?
Related Posts
PCB Thermal Management for Robot
How to design for Power, Motion, and Reliability
PCB Thermal Management for Robot
Read More
5 PCB Failures That Stop Robots
Learn the most common PCB failures in humanoid robotics.
5 PCB Failures That Stop Robots
Read More
What is a PCB Trace?
A Guide to Width, Current, Spacing, and Reliability
What is a PCB Trace?
Read More
Browse
All Categories
Recent Posts
View Recent Posts